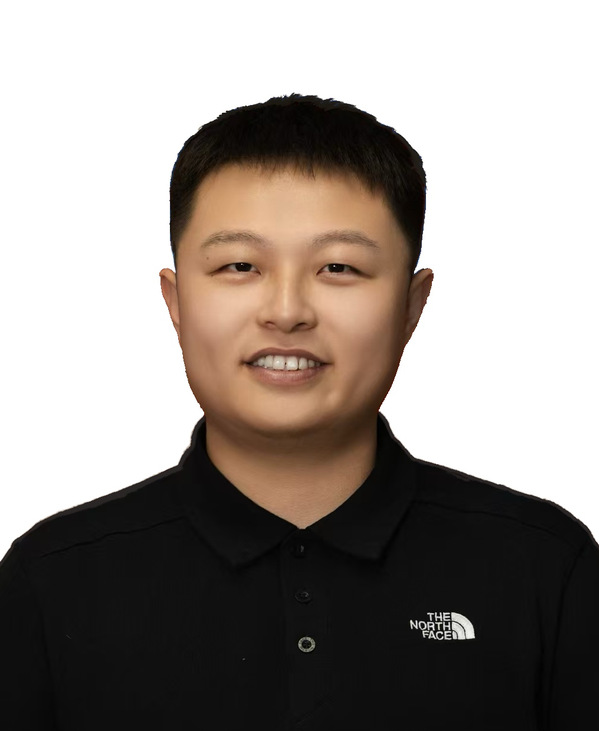


| 周勇 |
助理研究员 | |
邮箱:zhou_yong@upc.edu.cn 办公地点:国工楼513 | |
 教育经历 | |
2015.09-2019.06 | 山东大学机械设计制造及其自动化专业,工学学士 |
2019.09-2025.12 | 浙江大学机械工程专业专业,工学博士 |
 工作经历 | |
2025.12-至今 | 中国石油大学(华东)机电工程学院助理研究员、博士后 |
 研究领域/招生方向 | |
[1] 电液控制理论及工程应用 [2] 精密机电系统高性能运动控制 [3] 人工智能技术及工程应用 [4] 海洋工程装备与智能控制 | |
 主持项目 | |
[1] 青岛市自然科学基金青年基金,2026.05-2028.04,主持 [2] 国家重点研发计划课题,“水下EHA 一体化优化设计与制造”(2023YFC2809903),2023.12-2026.11,参与 [3] 国家重点研发计划课题,“阀口独立控制系统的控制策略与安全风险评估”(2020YFB2009703),2020.10-2023.09,参与 [4] 振华重工,“门式起重机主动防摇与精准定位控制研究”,参与 [5] 流体动力基础件与机电系统全国重点实验室开放基金,“基于机器学习的移动机械工作环境智能感知与控制”,参与 | |
 学术论文 | |
[1] Yong Zhou, Xinyu Zhang, Bobo Helian*, Zheng Chen*, Bin Yao. MIMO adaptive robust synchronization control of an electro-hydraulic dual-cylinder system with rotational dynamics compensation[J]. IEEE Transactions on Automation Science and Engineering, 2026, 23: 15489-15502. DOI: 10.1109/TASE.2026.3728526. [2] Yong Zhou, Ruqi Ding,* Min Cheng, Liqiu Liao, Zheng Chen, Bin Yao. Precision motion control of independent metering hydraulic swing system with large inertia loads: A case study on a rotary drilling rig[J]. IEEE Transactions on Industrial Electronics, 2025, 72(10): 10390-10400. DOI: 10.1109/TIE.2025.3549091. [3] Yong Zhou, Xinyu Zhang, Bobo Helian*, Zheng Chen*, Bin Yao. Adaptive robust synchronization control of an electro-hydraulic dual-cylinder system with dynamic thrust allocation[J]. IEEE/ASME Transactions on Mechatronics, 2025, 30(4): 2880-2888. DOI: 10.1109/TMECH.2025.3565833. [4] Yong Zhou, Bobo Helian*, Zheng Chen, Bin Yao. Adaptive robust constrained motion control of an independent metering electro-hydraulic system considering kinematic and dynamic constraints[J]. IEEE Transactions on Industrial Informatics, 2025, 21(8): 5943-5953. DOI: 10.1109/TII.2025.3556072. [5] Yong Zhou, Zheng Chen*, Ruqi Ding, Min Cheng, Bin Yao. Precision motion control of separate meter-in and separate meter-out hydraulic swing system with state constraints[C].Advances in Mechanism, Machine Science and Engineering in China: Proceedings of IFToMM CCMMS 2022. Singapore: Springer, 2023: 35-55. DOI: 10.1007/978-981-19-9398-5_3. [6] Zheng Chen, Bobo Helian*, Yong Zhou, Marcus Geimer. An integrated trajectory planning and motion control strategy of a variable rotational speed pump-controlled electro-hydraulic actuator[J]. IEEE/ASME Transactions on Mechatronics, 2023, 28(1): 588-597. DOI: 10.1109/TMECH.2022.3209873. [7] Guanghui Li, Xiaocong Zhu*, Jian Cao, Yong Zhou. Backstepping adaptive robust control for precision tracking of flexible link manipulators[C]. 2025 IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM). IEEE, 2025: 1-6. DOI: 10.1109/AIM64088.2025.11175755. [8] Bobo Helian*, Xiaofei An, Yong Zhou, Zheng Chen, Marcus Geimer. LSTM-based workload recognition for hydraulic actuators: A case study on excavator digging process[C]. BATH/ASME 2024 Symposium on Fluid Power and Motion Control. New York: American Society of Mechanical Engineers, 2024: V001T01A013. DOI: 10.1115/FPMC2024-140092. [9] 丁儒琦, 廖礼求, 李刚*, 周勇, 邱江俊, 秦武. 基于阀口独立控制的大惯量电液回转系统精密运动控制[J/OL]. 机械工程学报, 2026-02-05. | |
 中国发明专利 | |
[1] 陈正,周勇,张军辉,徐兵,姚斌,负载口独立控制的大惯量旋挖钻机上车回转系统控制方法,授权日:2023.01.13,中国,ZL 202111485259.6. | |
 获奖荣誉 | |
[1] 2022年,第23届中国机构与机器科学及应用会议(IFToMM CCMMS2022)最佳会议论文提名 | |
学术兼职 | |
[1] IEEE 会员、中国自动化学会会员 [2] 担任 Chinese Journal of Mechanical Engineering(CJME)、IEEE Transactions on Automation Science and Engineering(TASE)、IEEE Transactions on Industrial Electronics(TIE)、IEEE Transactions on Industrial Informatics(TII)等期刊审稿人 | |